LHD, early detection of silent training failures in neural networks
Caught 87% of broken training runs, usually by epoch 3, with 2% false alarms.
Read the paper
I'm 15 and a sophomore in Frisco, Texas.
I'm interested in machine learning.
I also code for FRC Team 2714 and play soccer and tennis.
Caught 87% of broken training runs, usually by epoch 3, with 2% false alarms.
Read the paperI write Java for FRC Team 2714 and Team 2728, mostly autonomous routines and Limelight vision.
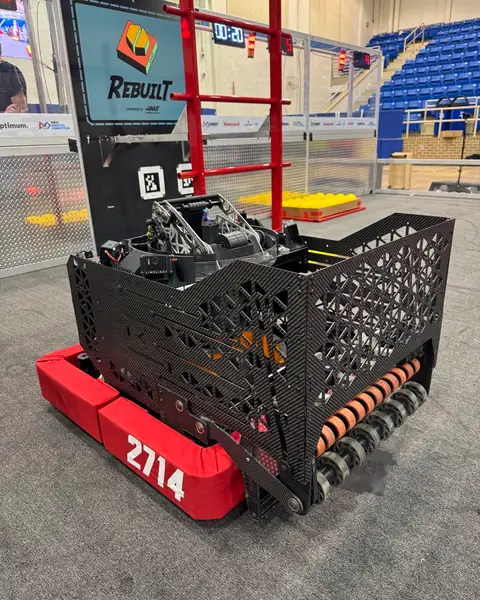
PathPlanner autos from three starting spots that shoot the preload, then make one or two trips to the neutral zone to pick up more and shoot again. I wrote 11 of the robot’s 12 autonomous routines.
CodeTwo Limelights feed MegaTag2 poses into the robot’s position estimate, skipping frames while it spins faster than one turn a second. A PID loop then turns it to face the hub and counts it aligned within 0.3°.
CodeA tablet app that lets the drive team tap anywhere on the field to set a passing target. The robot then aims there instead of using auto-aim.
Code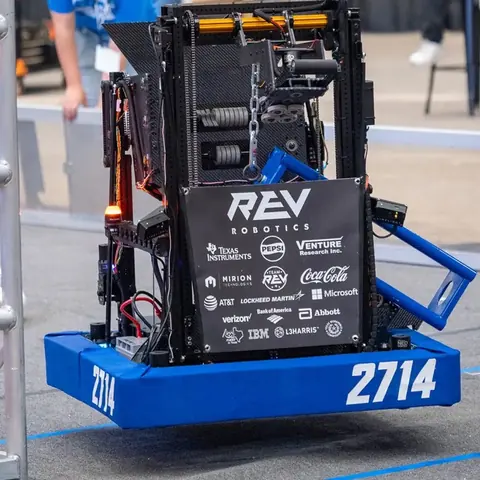
It lights up which of the reef’s 12 stalks the operator picked, and the match clock changes color with 30 and 15 seconds left. It won the team the Innovation in Control Award, sponsored by nVent, at the Texas state championship.
CodeTeam 2714 won the Fort Worth District event in 2025 and 2026.
Team 2714 on The Blue Alliance